Localize and associate semantic regions
Outcome: turn directional learned evidence into auditable angular regions and, when multiple registered views agree, spatial object hypotheses.
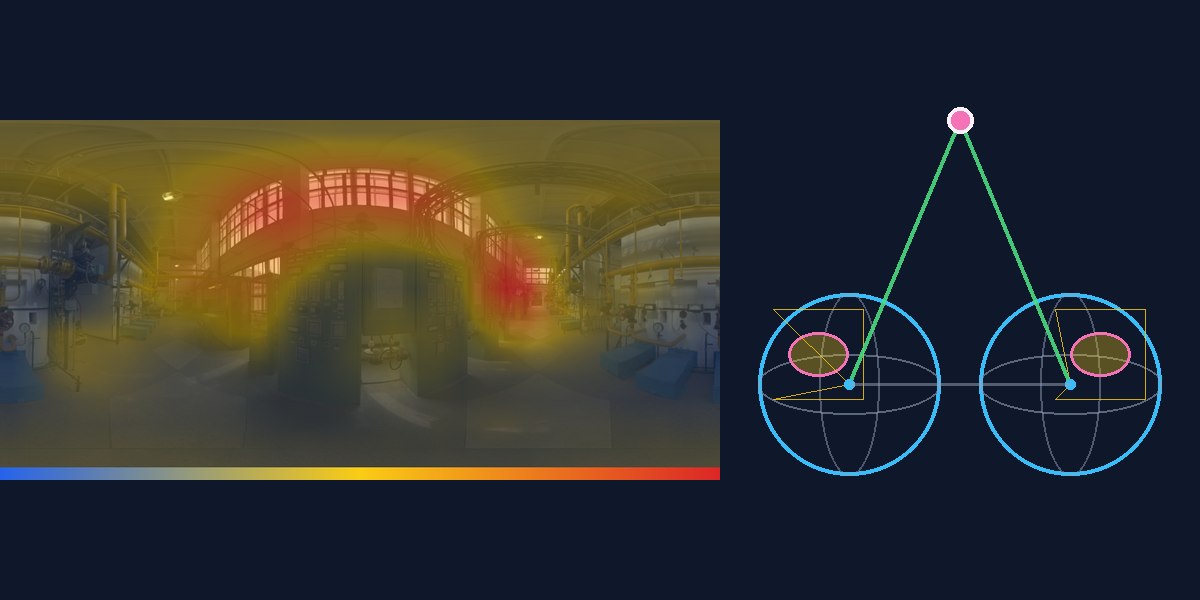
pretrained CNN -> spherical FCN -> CAM -> angular proposal
                                         |
                      registered views --+-> spatial hypothesis
                                         |
                                         +-> optional mask refinement
Start
Generate a spherical CAM with a pretrained classifier.
Interpret its resolution and support without treating it as a segmentation mask.
Build proposals
Convert evidence into finite angular and FOV proposals.
Associate views
Associate proposals across registered views and create a spatial hypothesis only when the evidence supports it.
Extend and evaluate
Optionally refine an accepted region with local masks.
Evaluate every stage without claiming ground-truth segmentation.