Estimate pose, depth and radial range
This application is a family of related problems. Choose the first unknown in your pipeline rather than treating pose and depth as one operation.
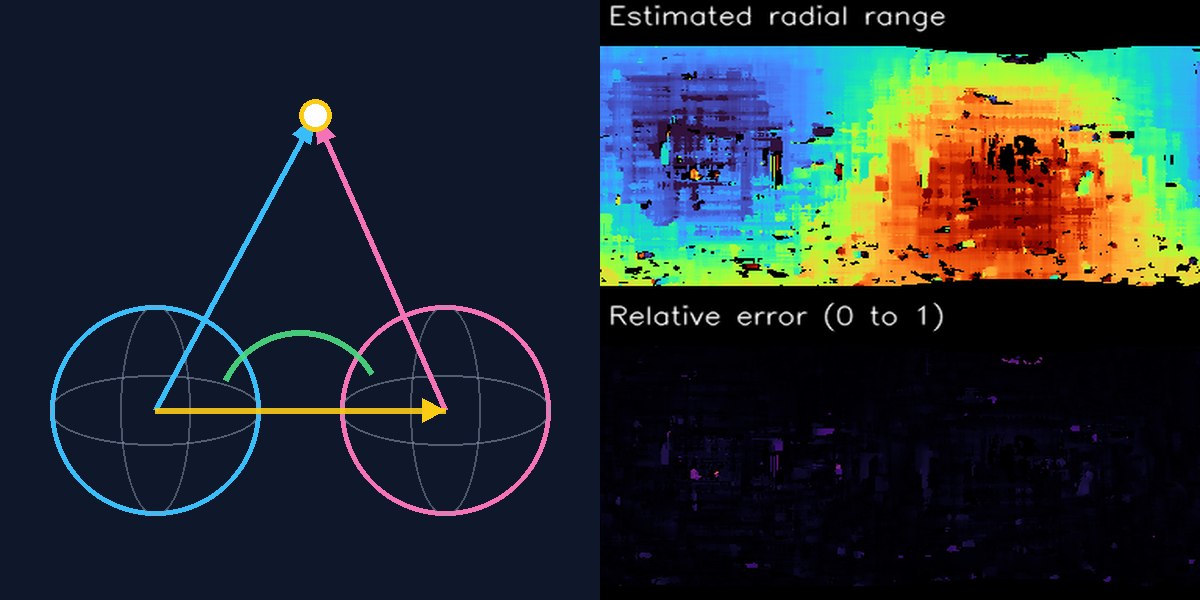
matched panoramas -> relative pose -> metric scale -> spherical stereo
one panorama      -> sphere-native CNN or tangent-view depth model
                                             |
                                             v
                              radial range + validity + provenance
Pose and scale
Estimate rotation and translation direction with relative pose.
Recover metric scale and triangulate accepted tracks.
Two-view dense range
Run the complete two-ERP workflow with panoramic dense stereo.
Use direct spherical stereo range when the sphere-native estimator is specifically required, or compare the classical rectified matchers at their pinhole input.
Multiview surface reconstruction
Fuse registered metric ERPs into a world-frame surface with MVS, TSDF and Marching Cubes. This route starts from supplied camera poses; it does not estimate registration.
Single-view range
Port the Metric3D CNN directly to spherical operations.
Validate and consume
Validate radial range before creating points or accepting a range product.