Extract and match visual features
Outcome: obtain keypoints, descriptors, ERP coordinates and unit bearings that remain meaningful across the seam and can feed spherical pose estimation.
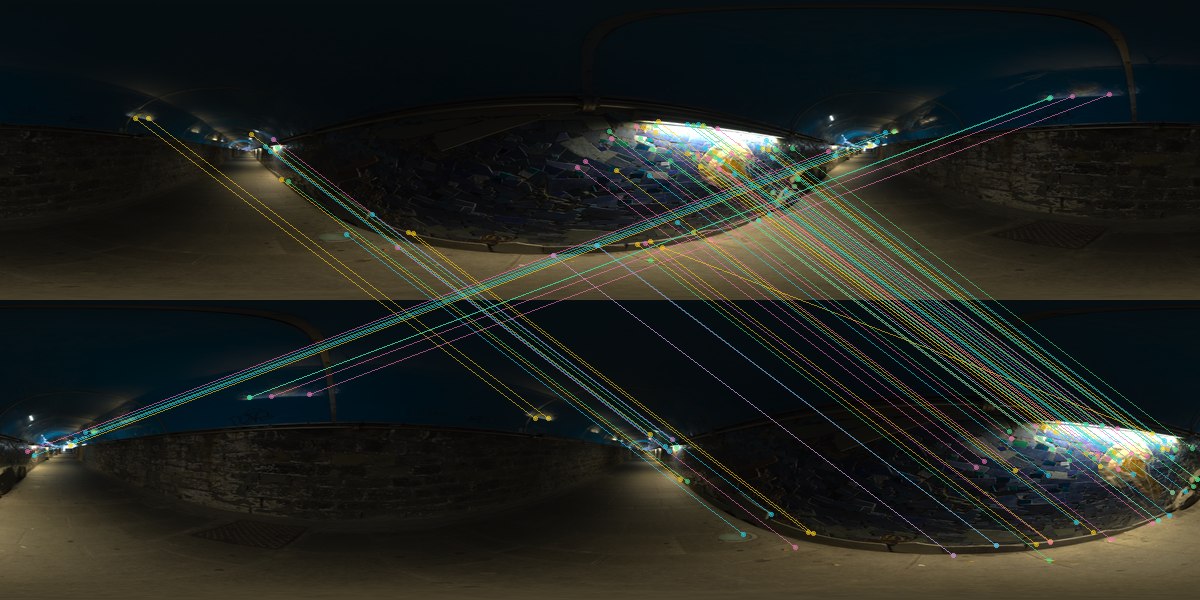
Start
Use the established face-based pipeline: extract and match spherical features.
Compose
Understand face sampling, bearing lifting and angular deduplication: projected features.
Extend
Detect scale-space extrema directly on the sphere: sphere-native features.
Evaluate
Match two panoramas and inspect descriptor and geometric diagnostics: matching and diagnostics.
The full detector comparison and parameter reference remain in the features tutorial.